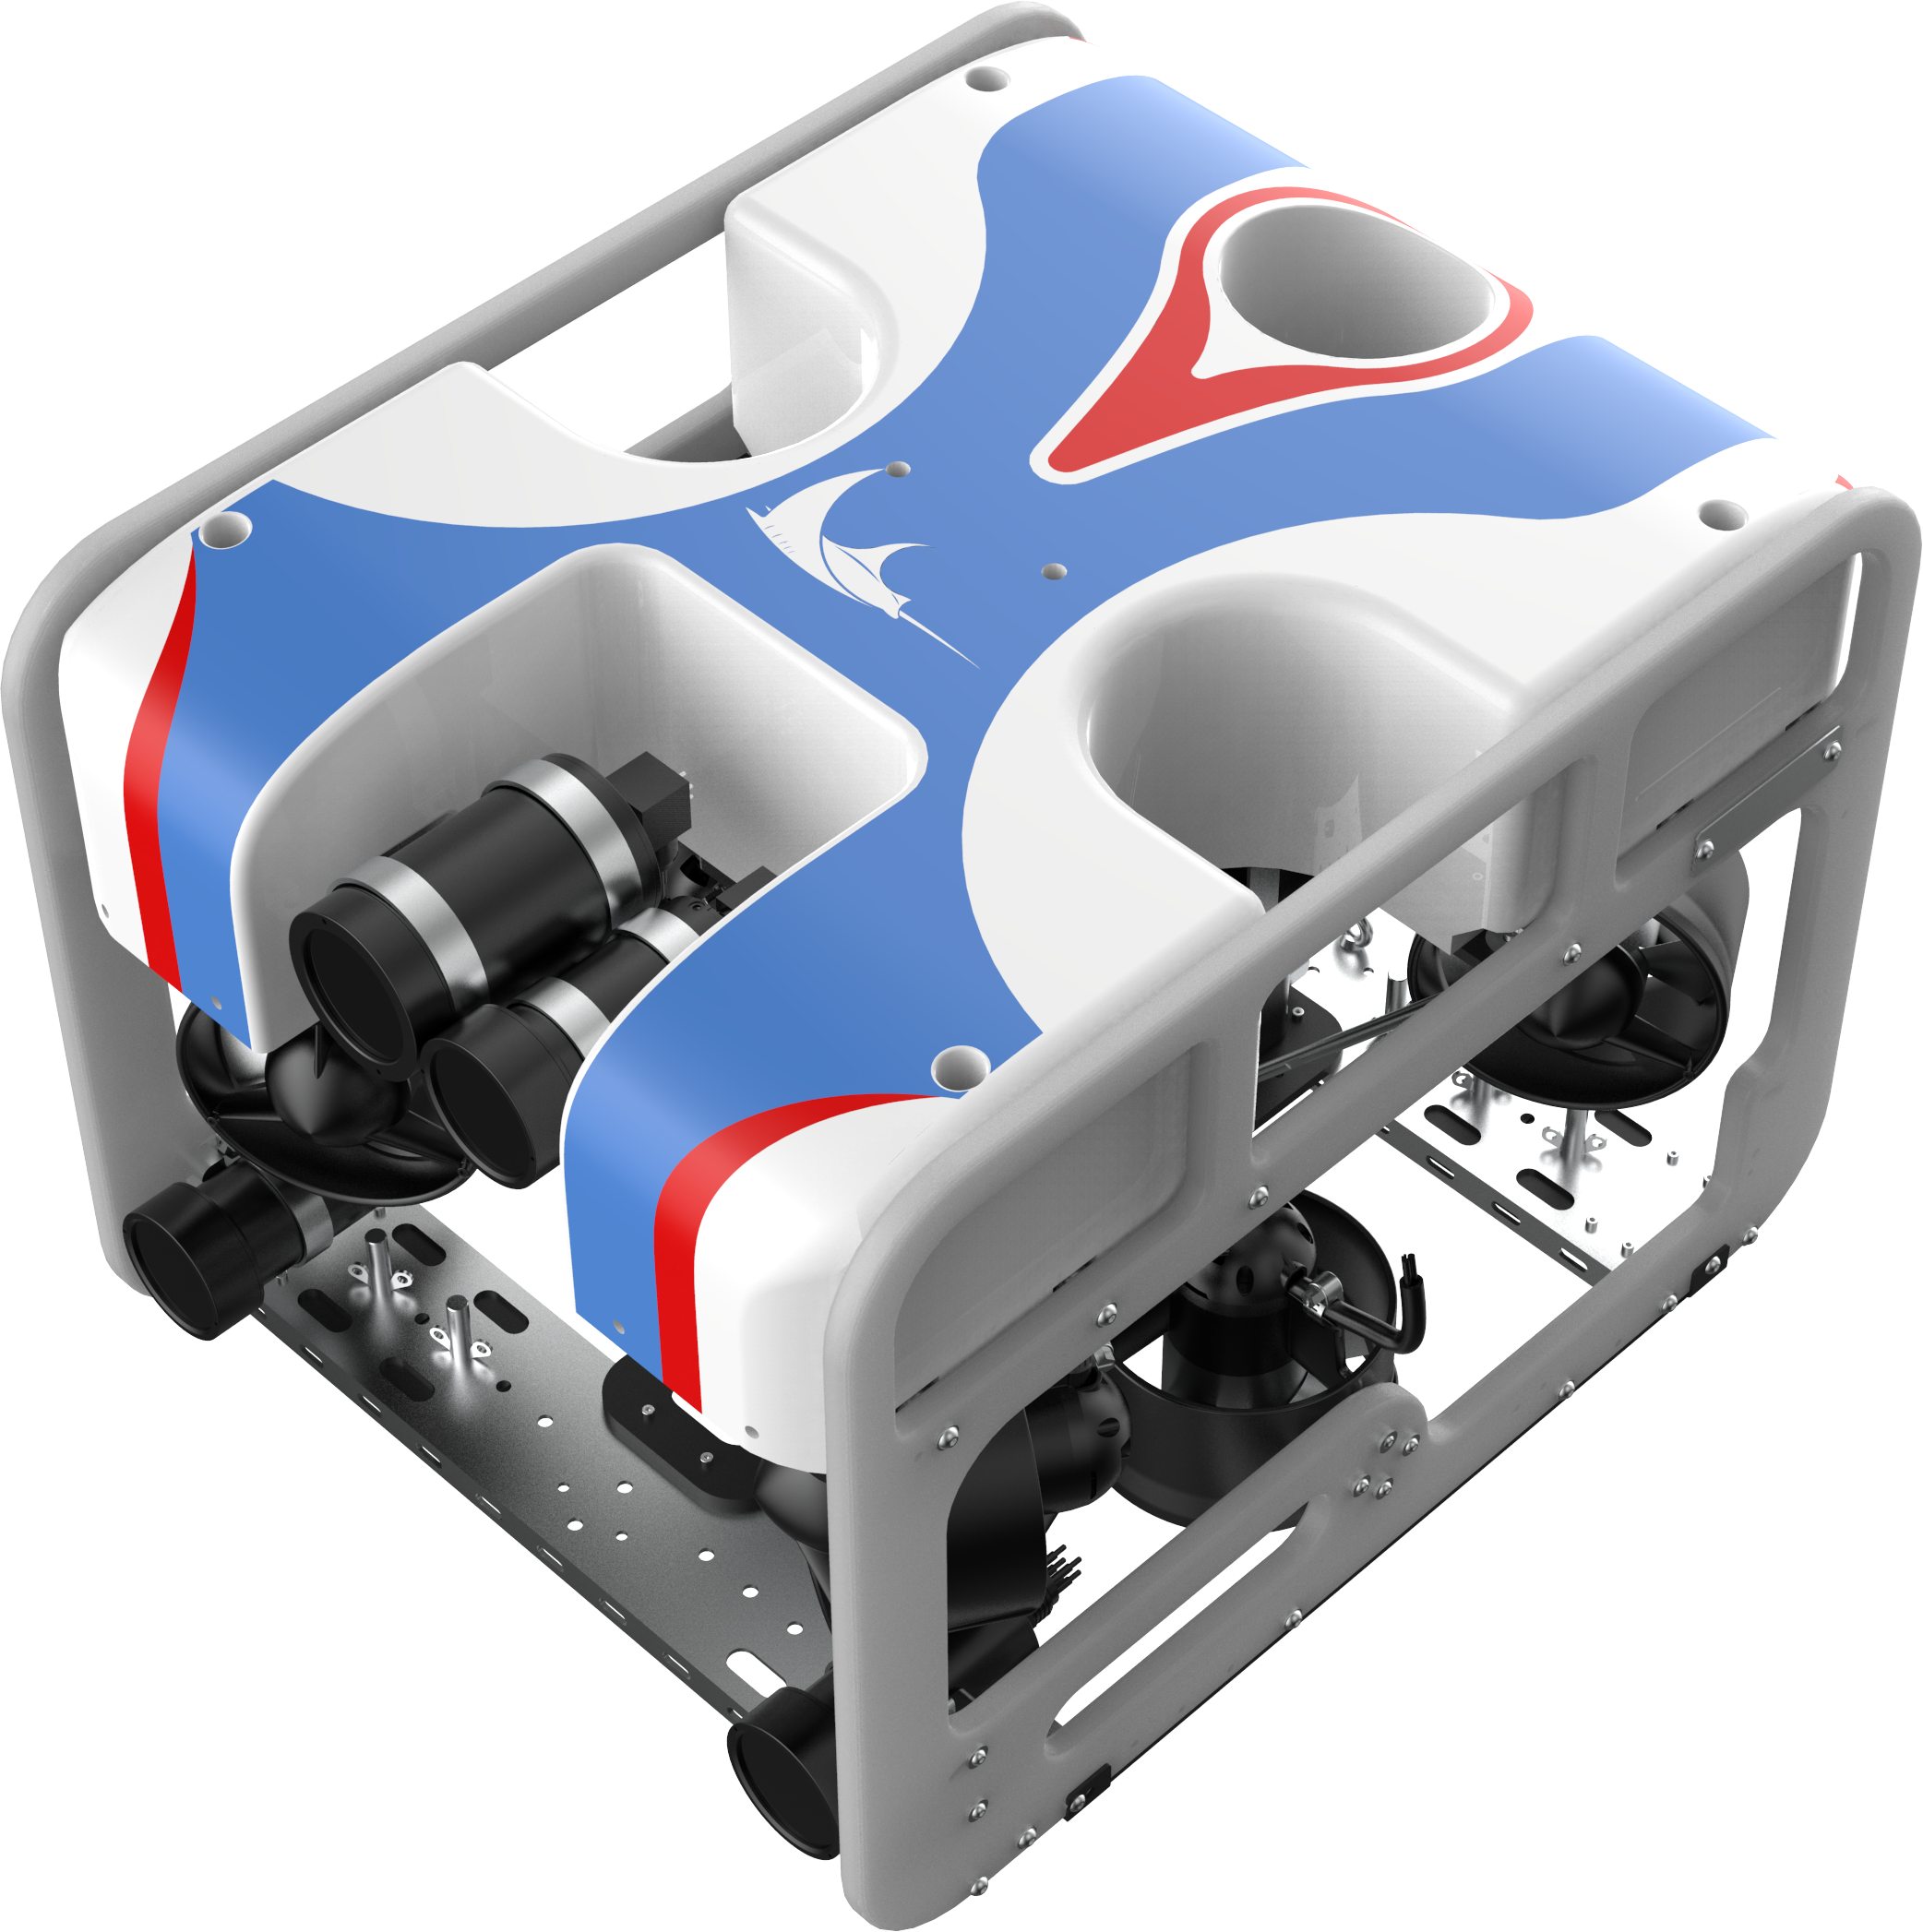
Inspection ROV
R-30
A tethered inspection ROV for visual assessment of submerged structures, with payload and sensor selection matched to the task.
View equipmentEQUIPMENT
Inspection, reach, contact cleaning and sediment removal each call for a different configuration.
A tethered inspection ROV for visual assessment of submerged structures, with payload and sensor selection matched to the task.
View equipment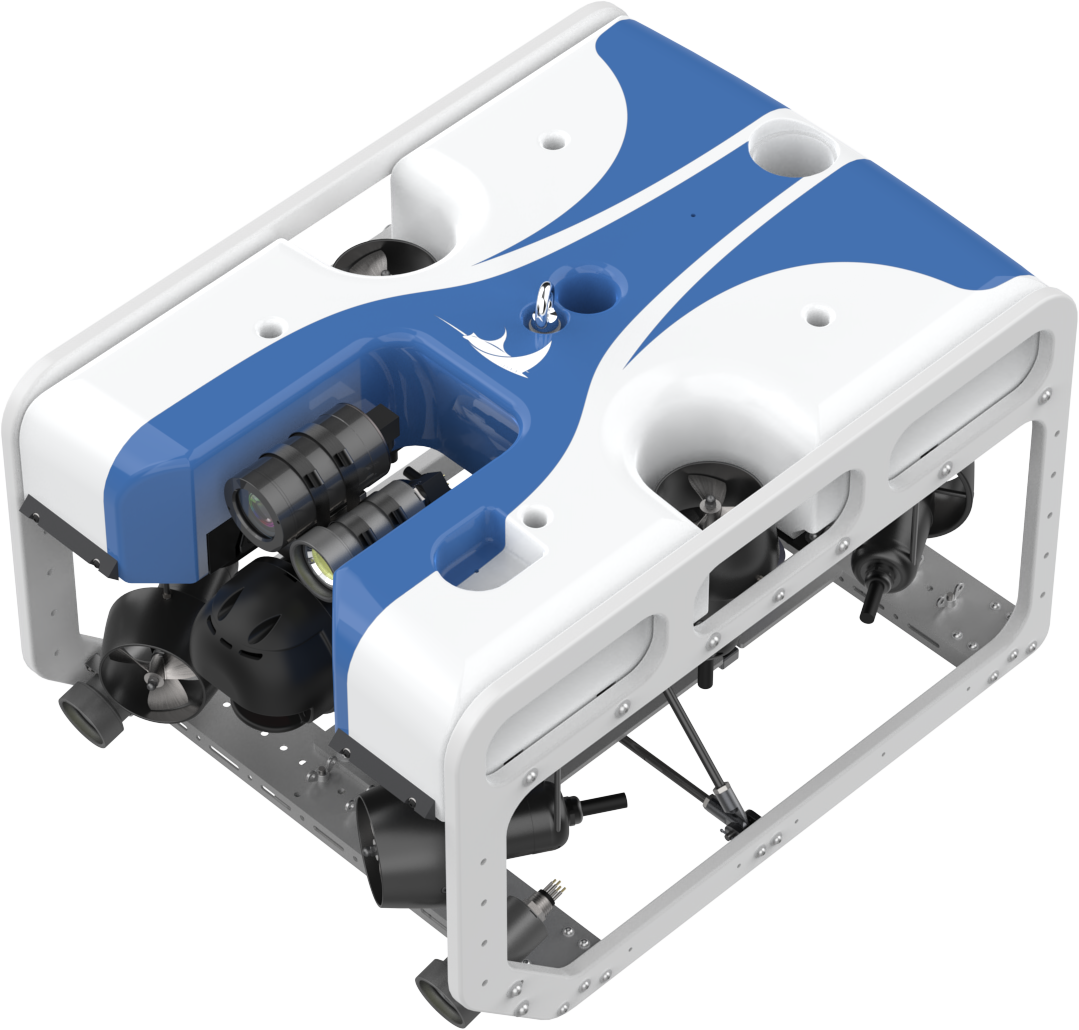
A tethered inspection platform with a higher brochure payload than the R-30, for projects needing additional sensing or tooling.
View equipment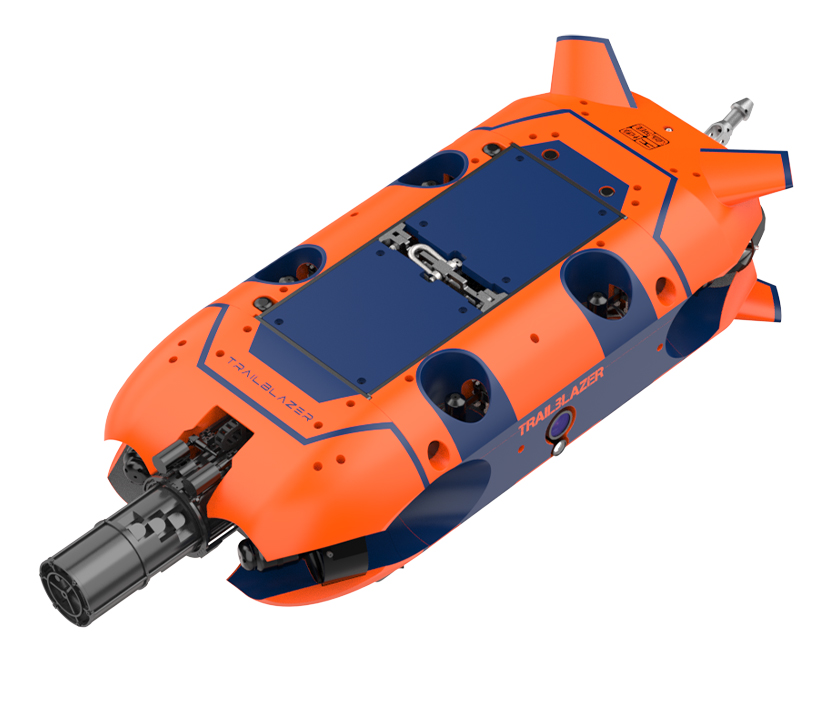
A specialist platform for long-distance inspection of flooded water tunnels, combining a tethered vehicle with project-specific sensing and tether management.
View equipment
A floating and crawling underwater platform described by the manufacturer for contact cleaning, with cavitation water-jet and brush configurations subject to application review.
View equipment
A remotely operated platform described in the manufacturer brochure for underwater sump dredging, with suction, conveyance and treatment selected together.
View equipmentAT A GLANCE
Vehicle figures from manufacturer materials; complete-system limits and supplied versions require confirmation.
| Model | Primary task | Vehicle weight | Depth | Review focus |
|---|---|---|---|---|
| R-30 | Inspection ROV | 21 kg | 300 m | Check clearance using the fully equipped vehicle dimensions. |
| R-45 | Inspection ROV | 42 kg | 350 m | Evaluate the complete payload and its effect on vehicle balance. |
| AD-400 | Tunnel inspection ROV | 300 kg | 1,000 m | Review tunnel geometry, bends, elevation profile and obstacles. |
| A-80 | Underwater cleaning robot | 100 kg | 300 m | Provide bar spacing, material, angle and access photographs. |
| AD-100 | Underwater dredging robot | 100 kg | Confirm for the supplied system | Provide particle size, solids content, debris and sediment depth. |
FROM TASK TO CONFIGURATION
Share the task, site conditions and required results. Build a clear brief for system selection.